+
Here the dataset
+Dataset keys for data condition: ['target']
+Dataset values type for data condition: ['_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager', '_GraphDataManager']
+
+

 +
 +
 +
 +
 +
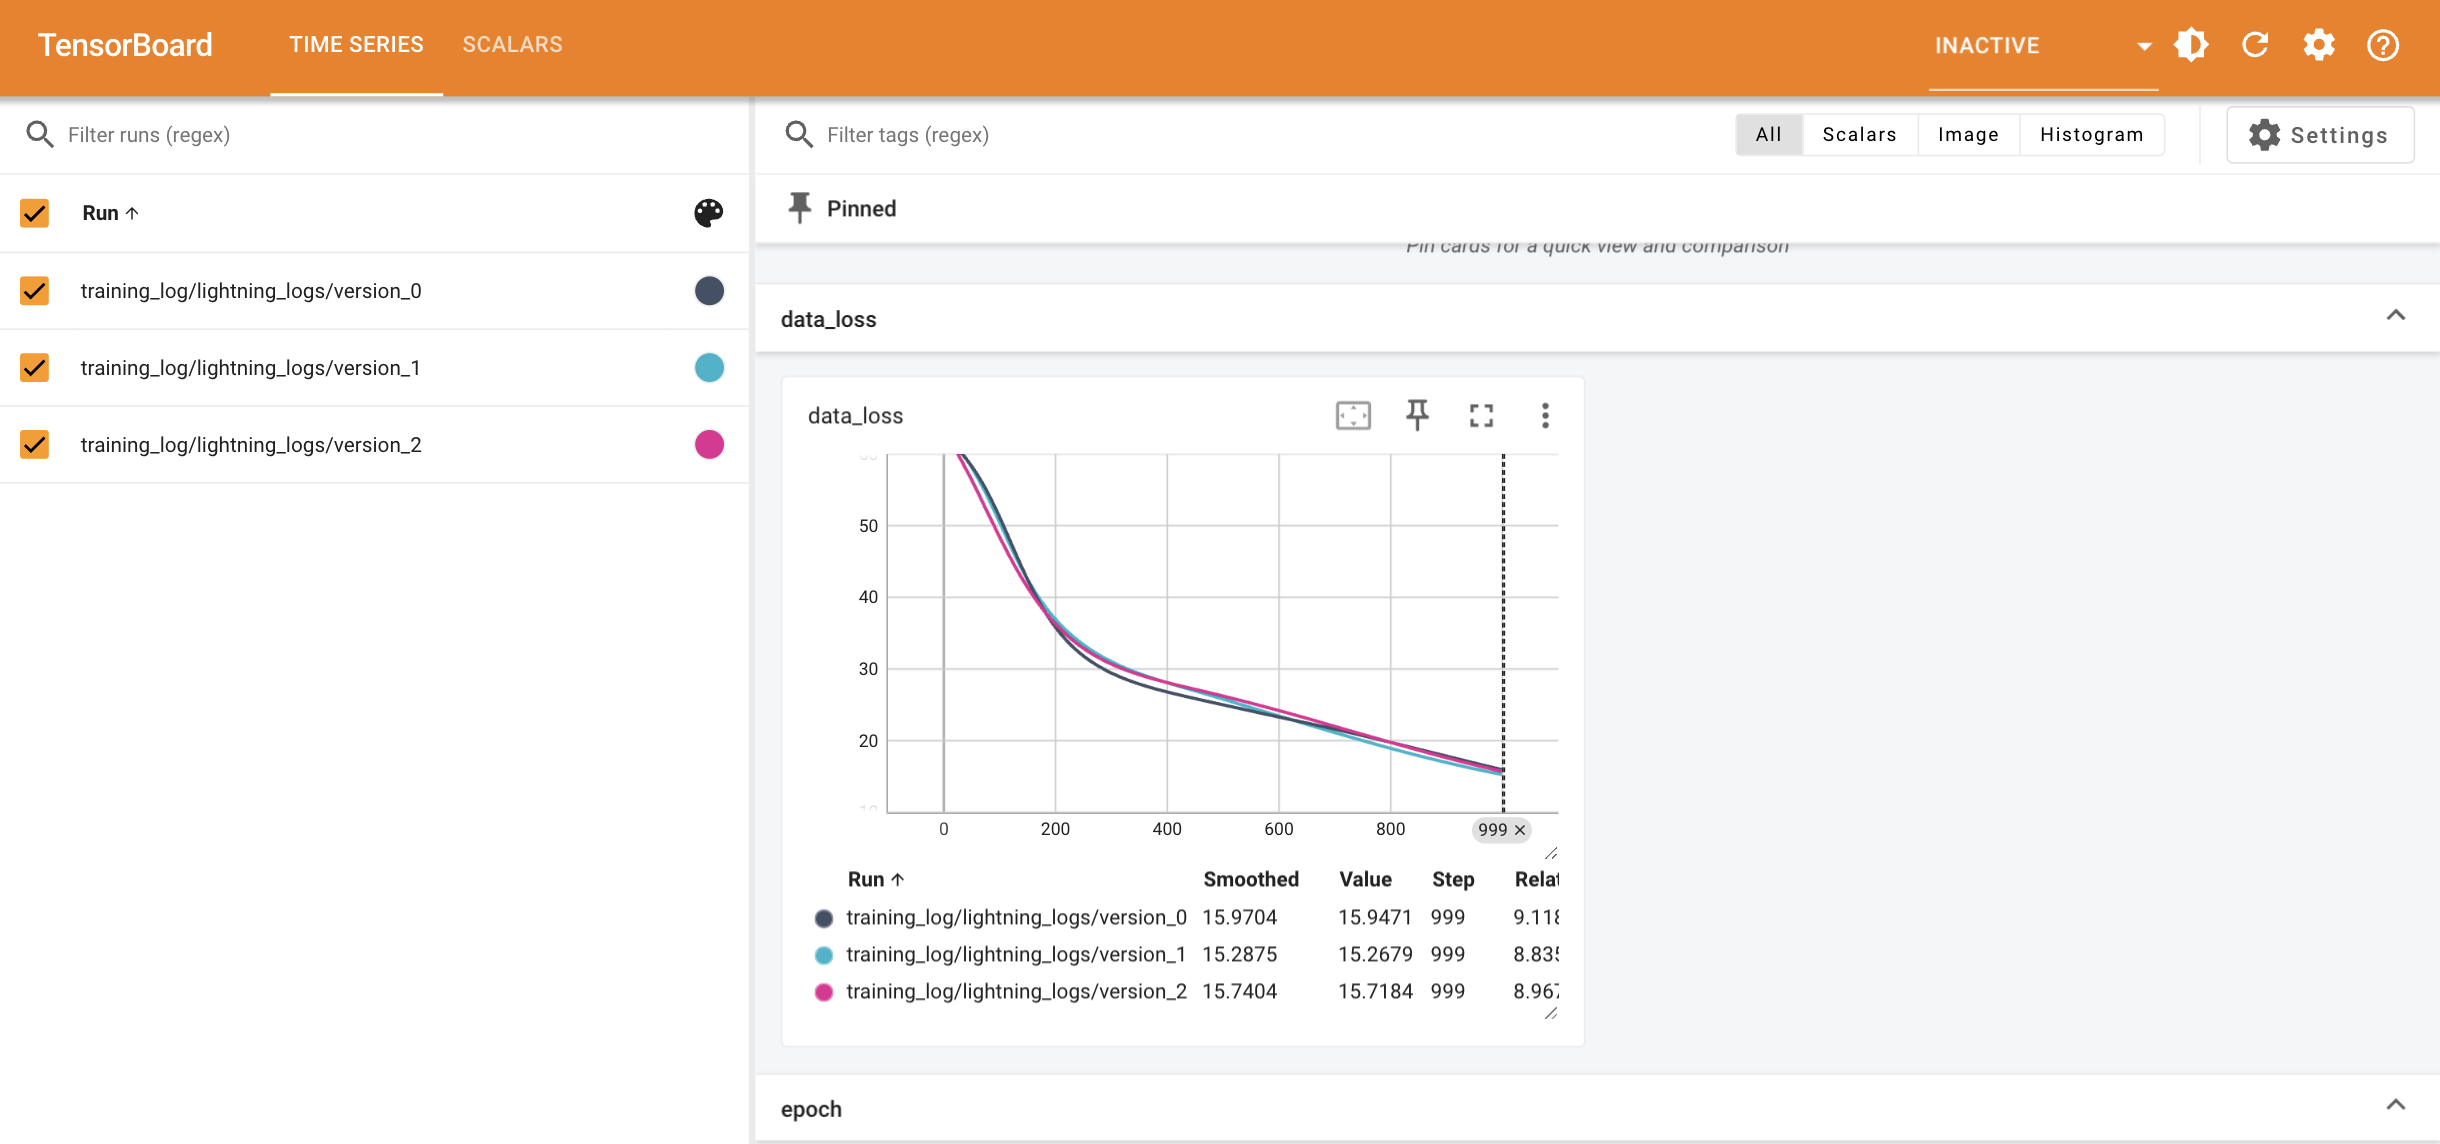 +
 +
 +
 +
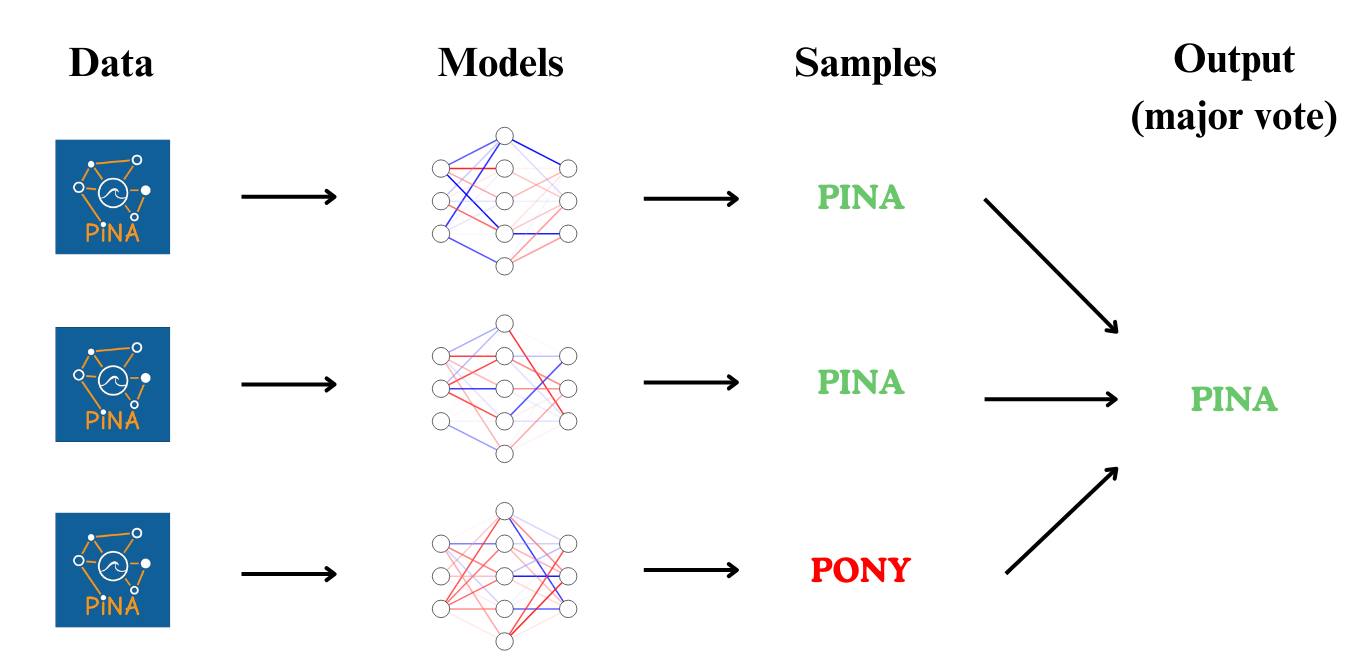 +
 +
 +
 +
 +
 +
 +
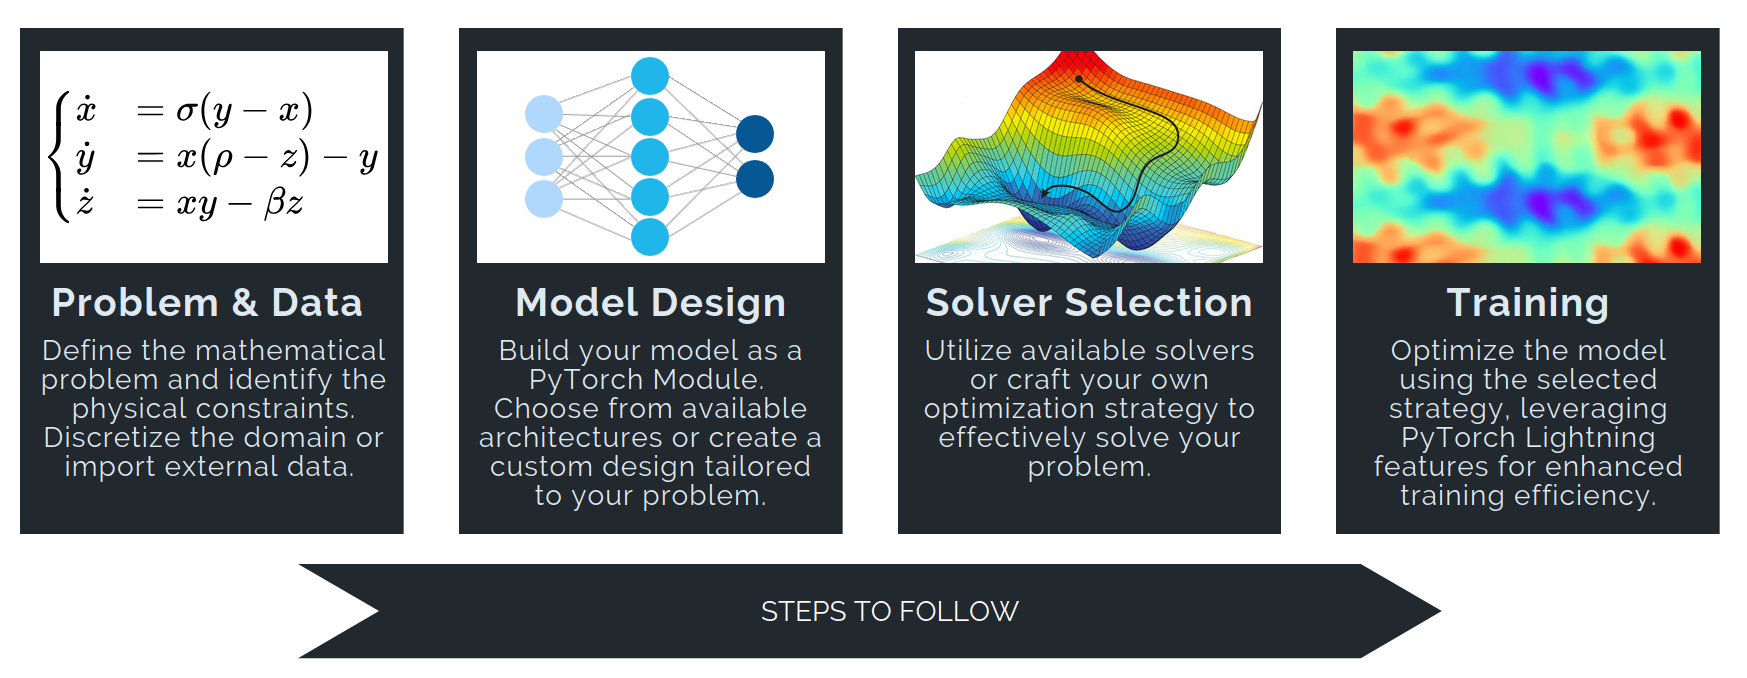 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
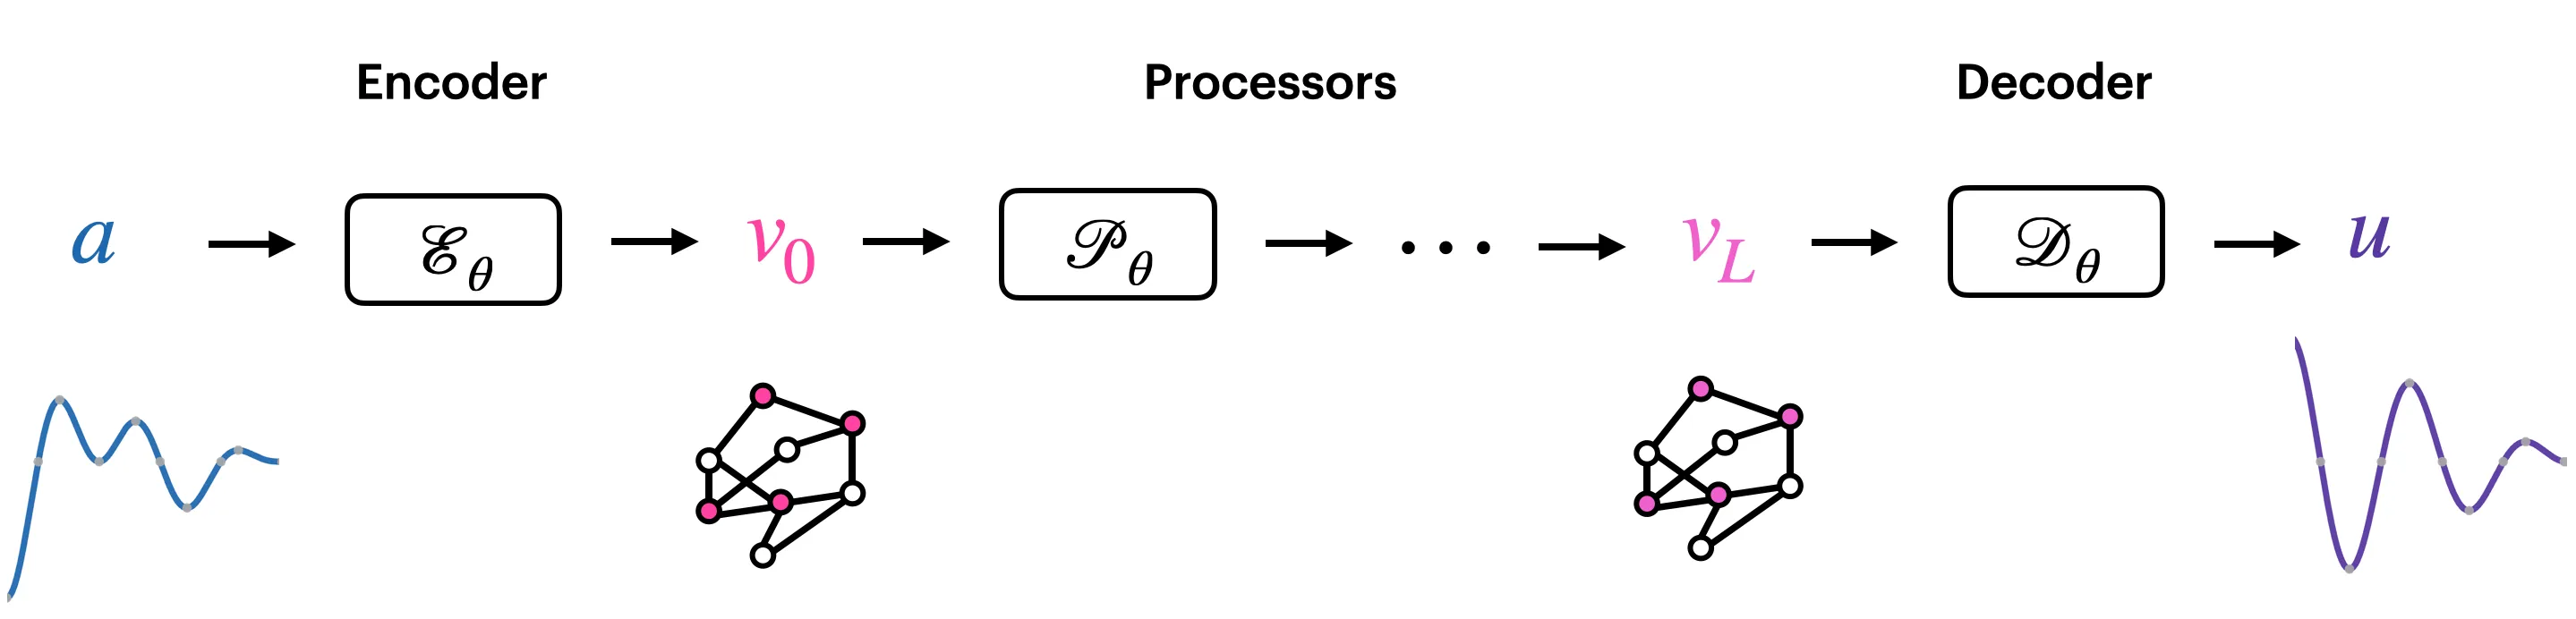 +
 +
 +
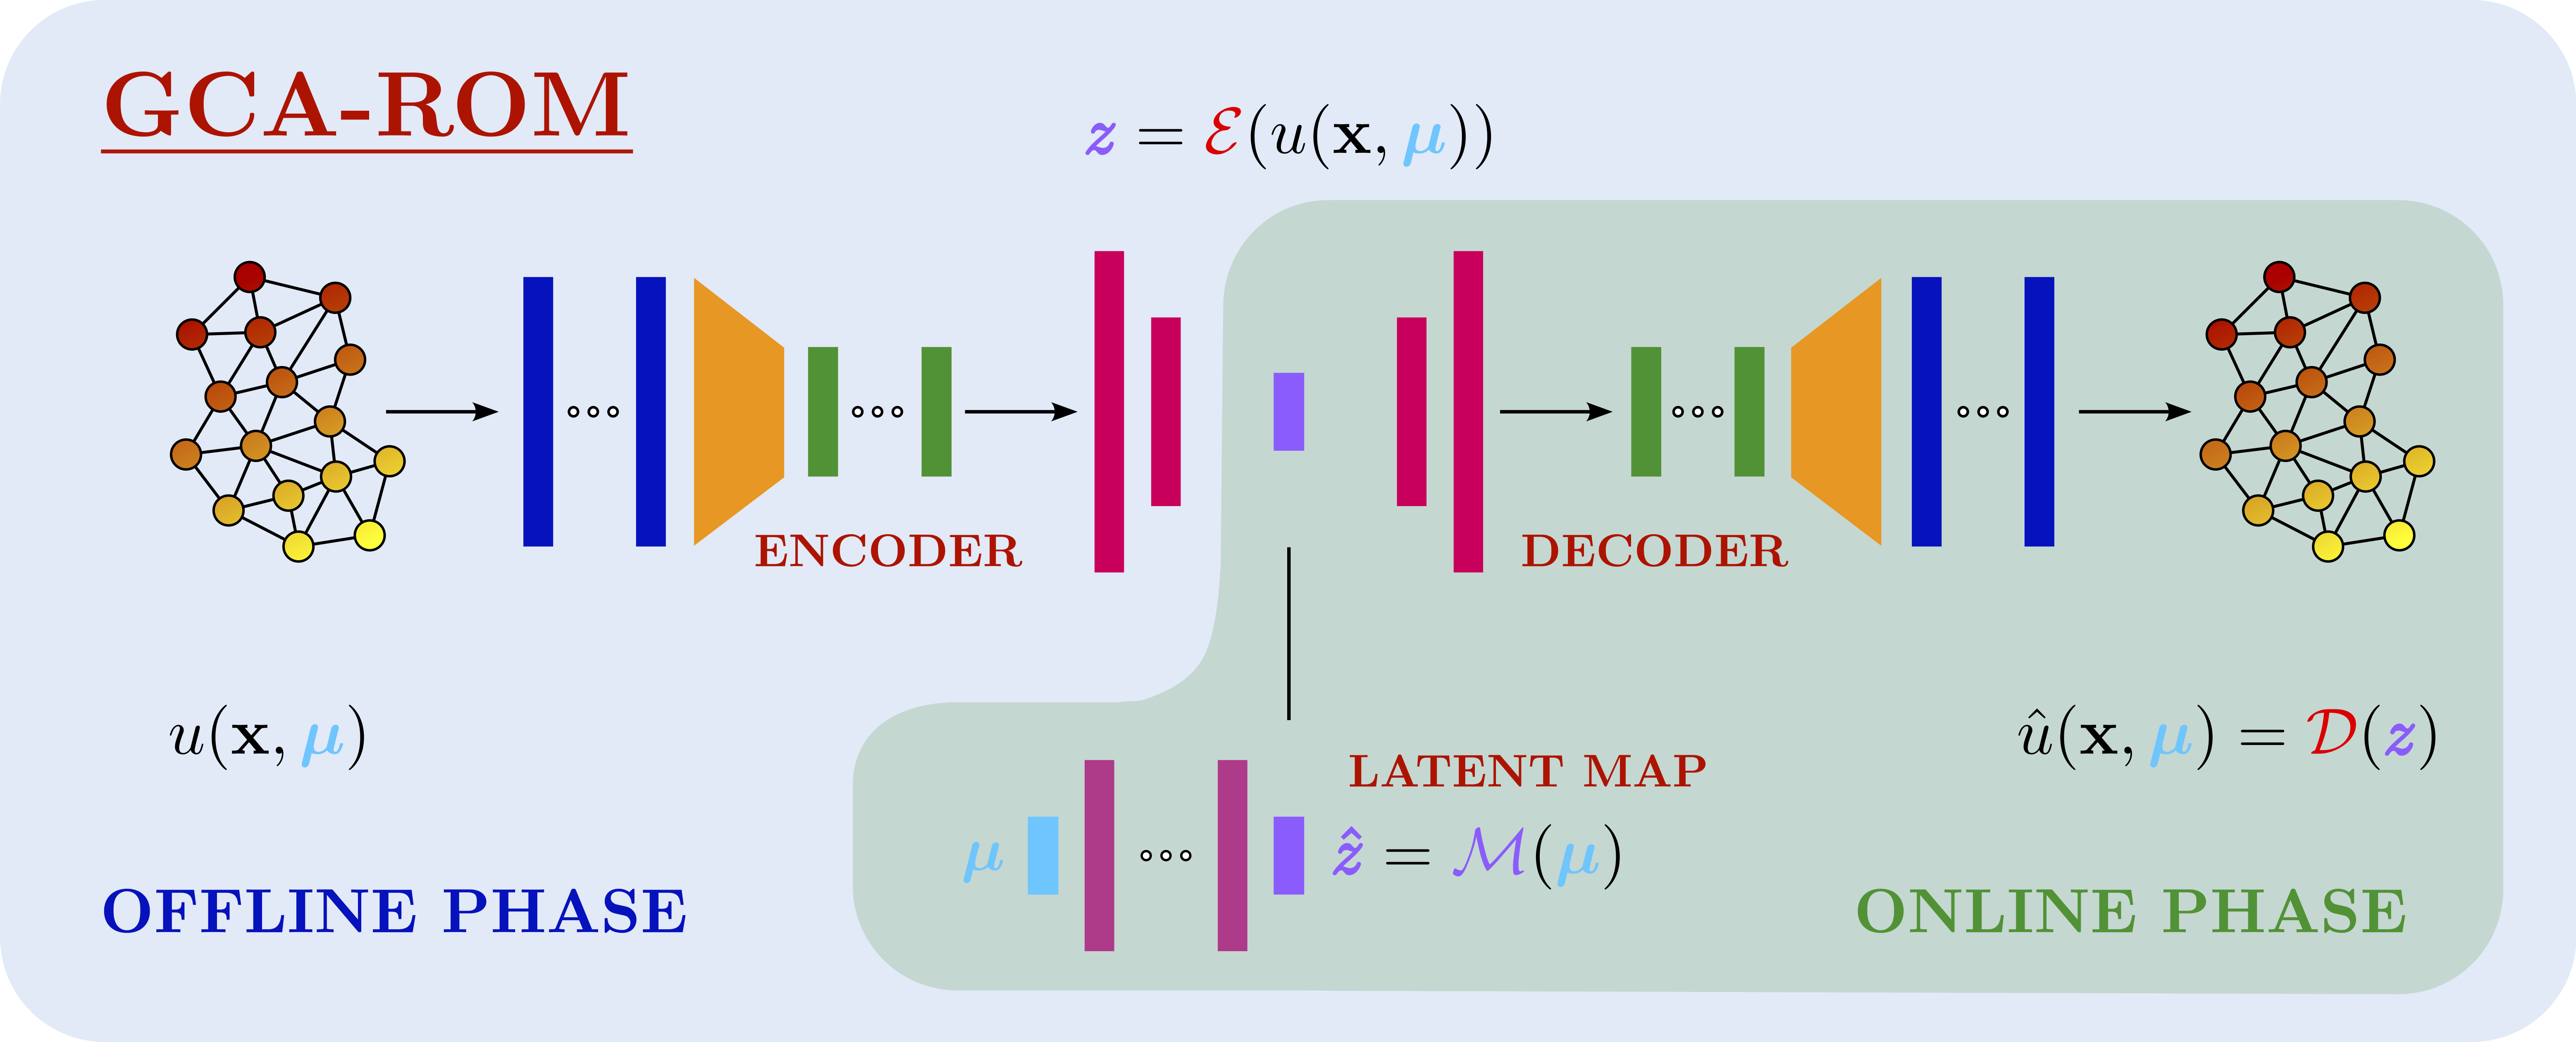 +
 +
 +
 +
 +
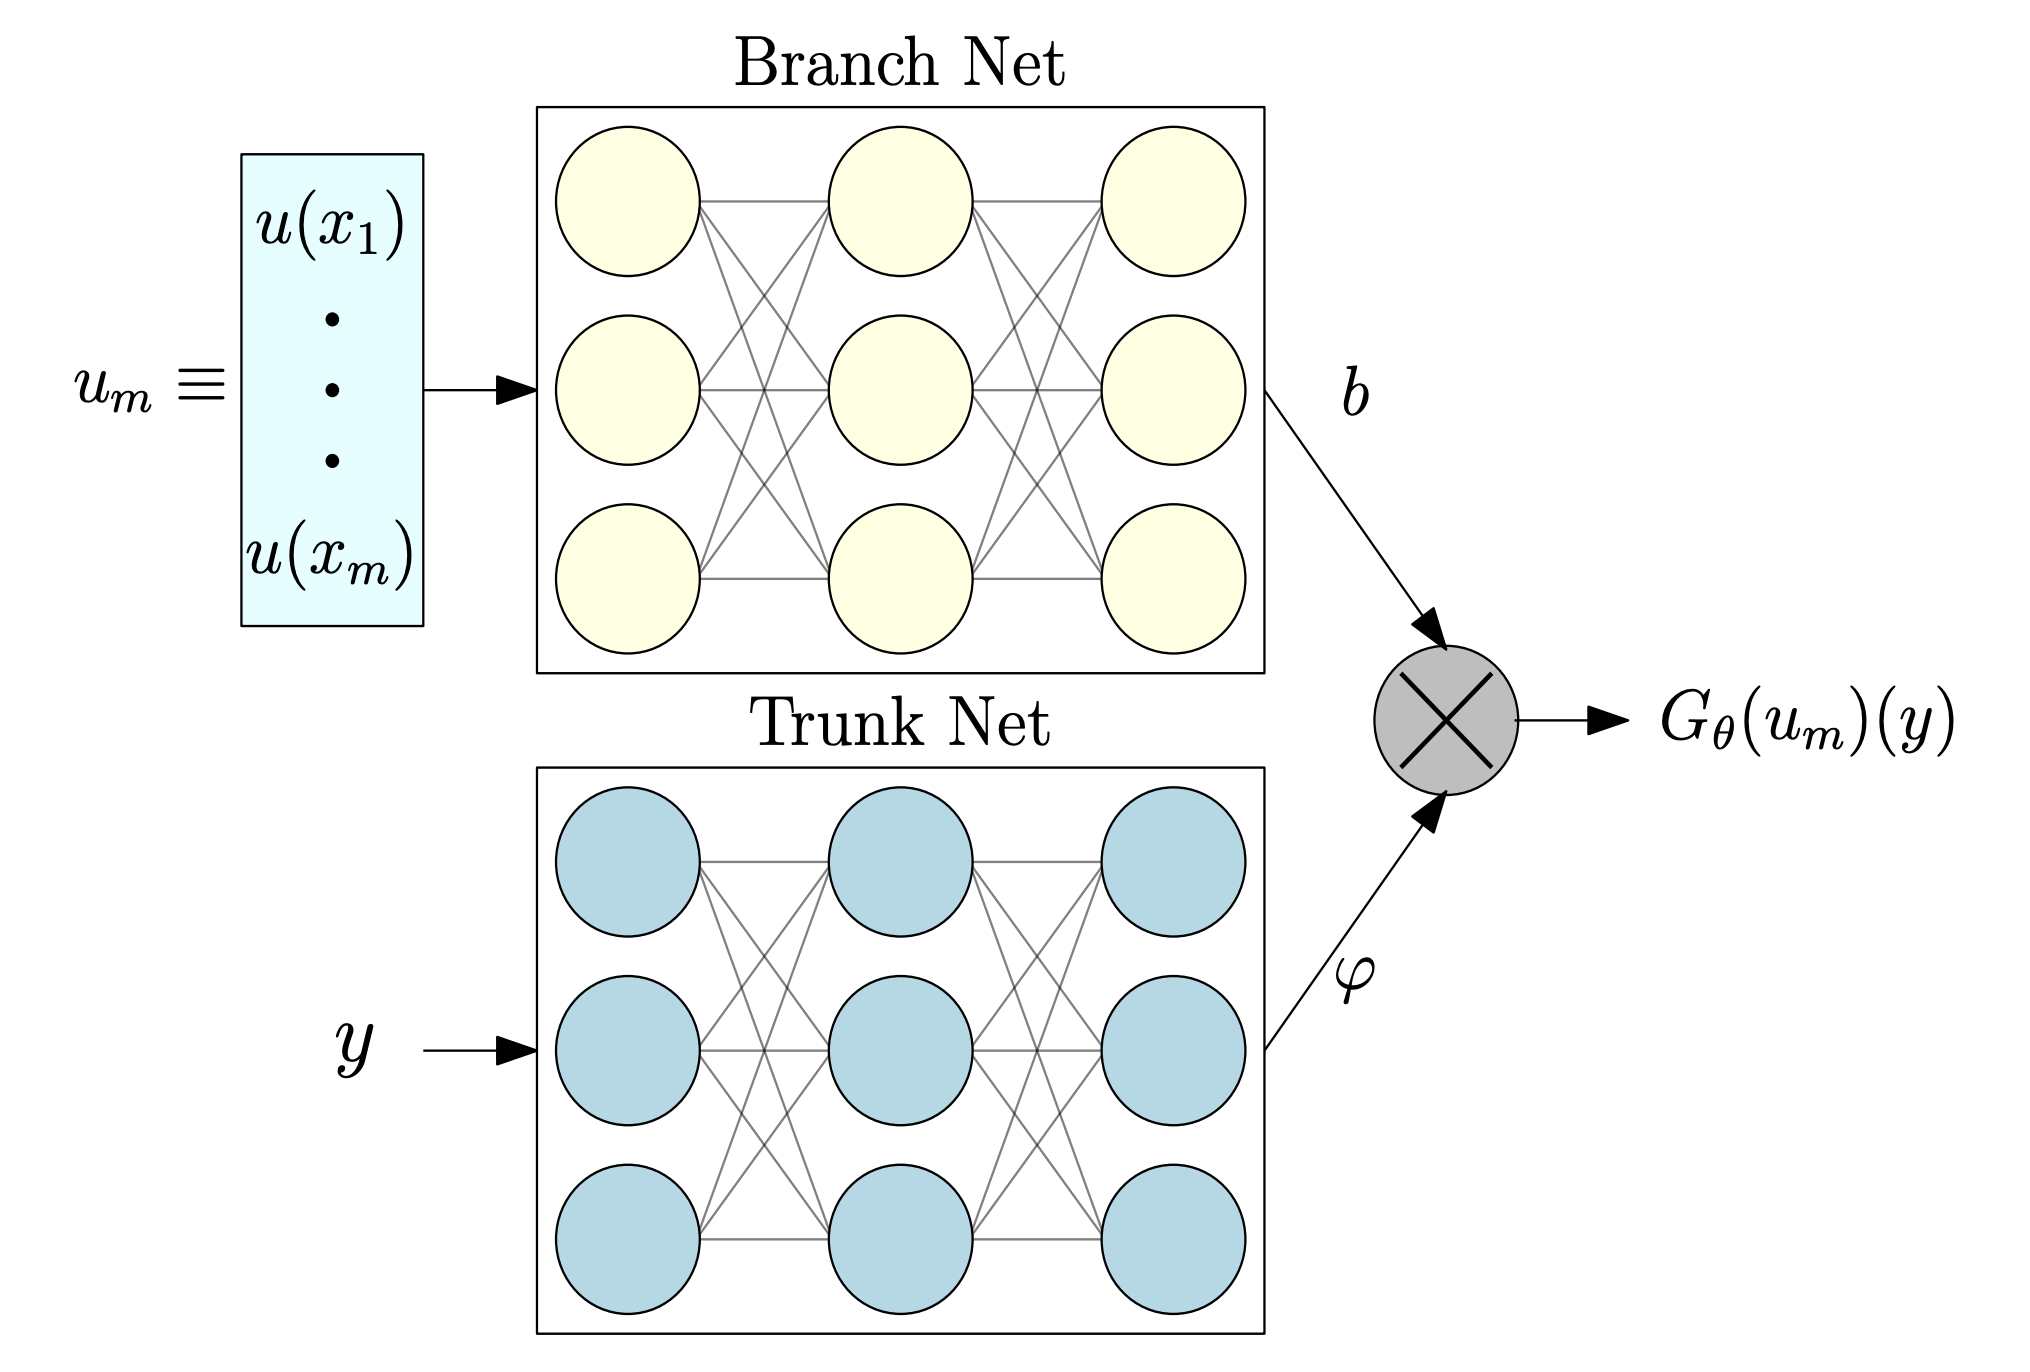 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +
 +#